PCB design, AI & WireFrame
Practical guides on board design, high-speed routing, moving from KiCad, sample boards and AI-assisted electronics.
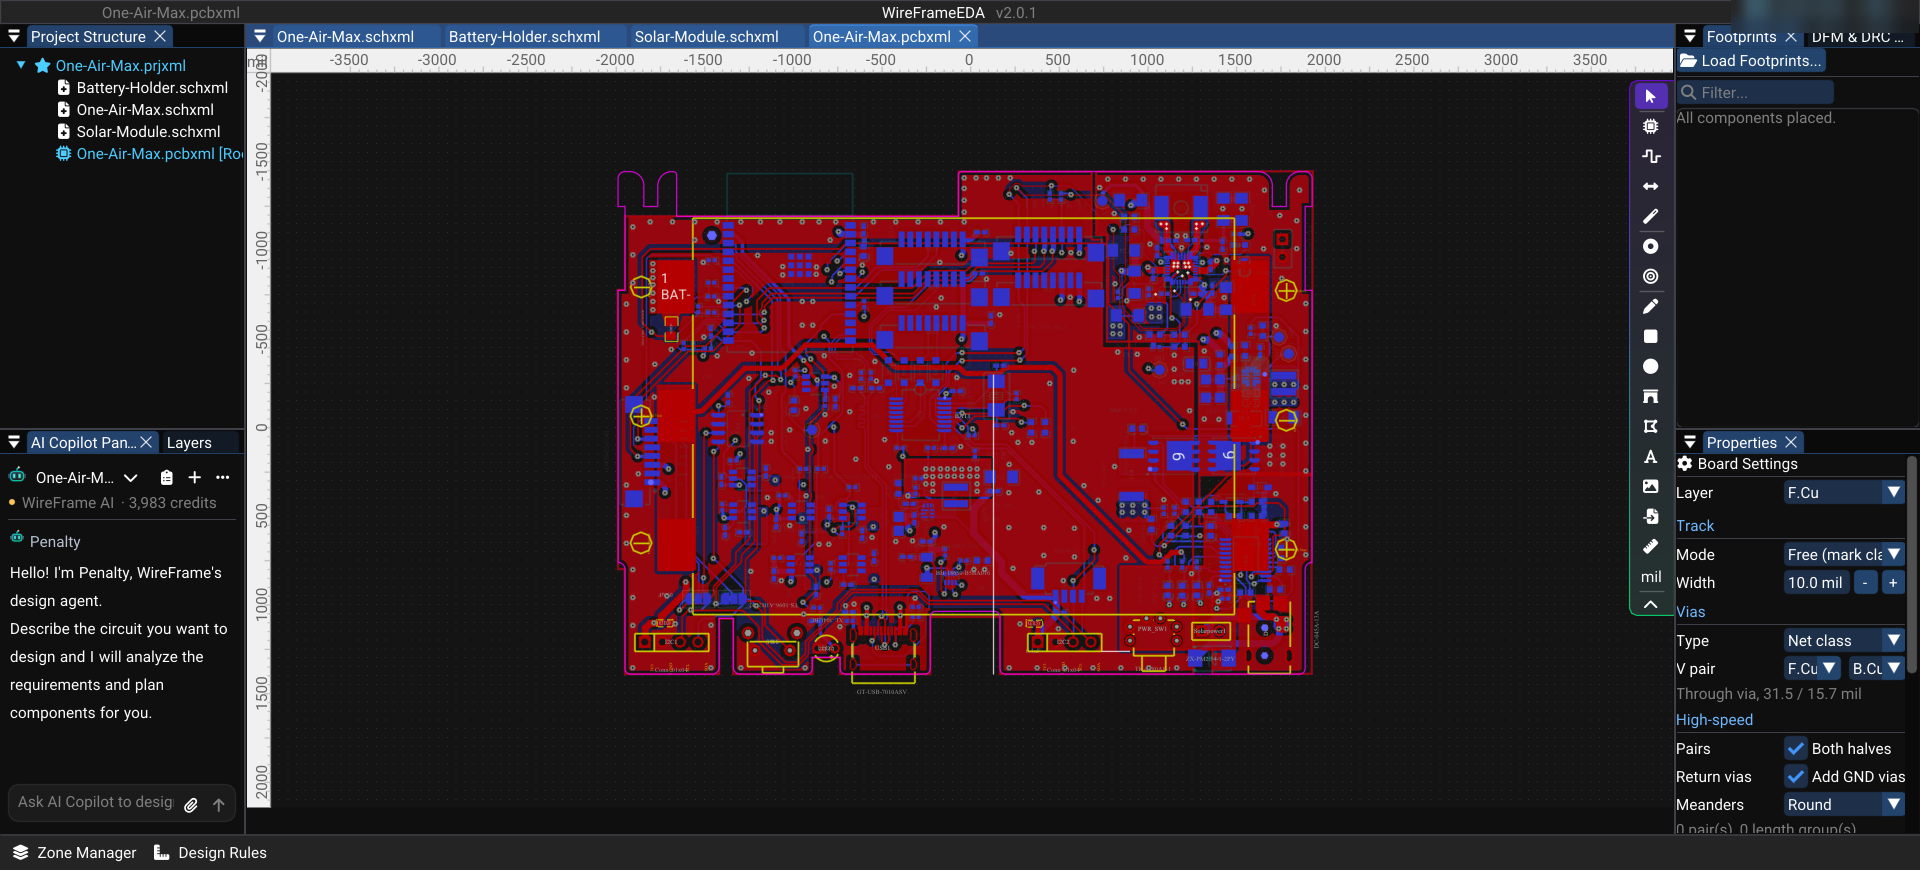
Sample board One-Air-Max — a 4-layer ESP32-C6 air-quality sensor with a PCB antenna, in WireFrame EDA
KiCad's One-Air-Max demo (ESP32-C6, solar and battery charging, buck converter, sensor front-end) imported into WireFrame EDA — its four-layer stackup and the keepout that keeps copper away from the antenna.
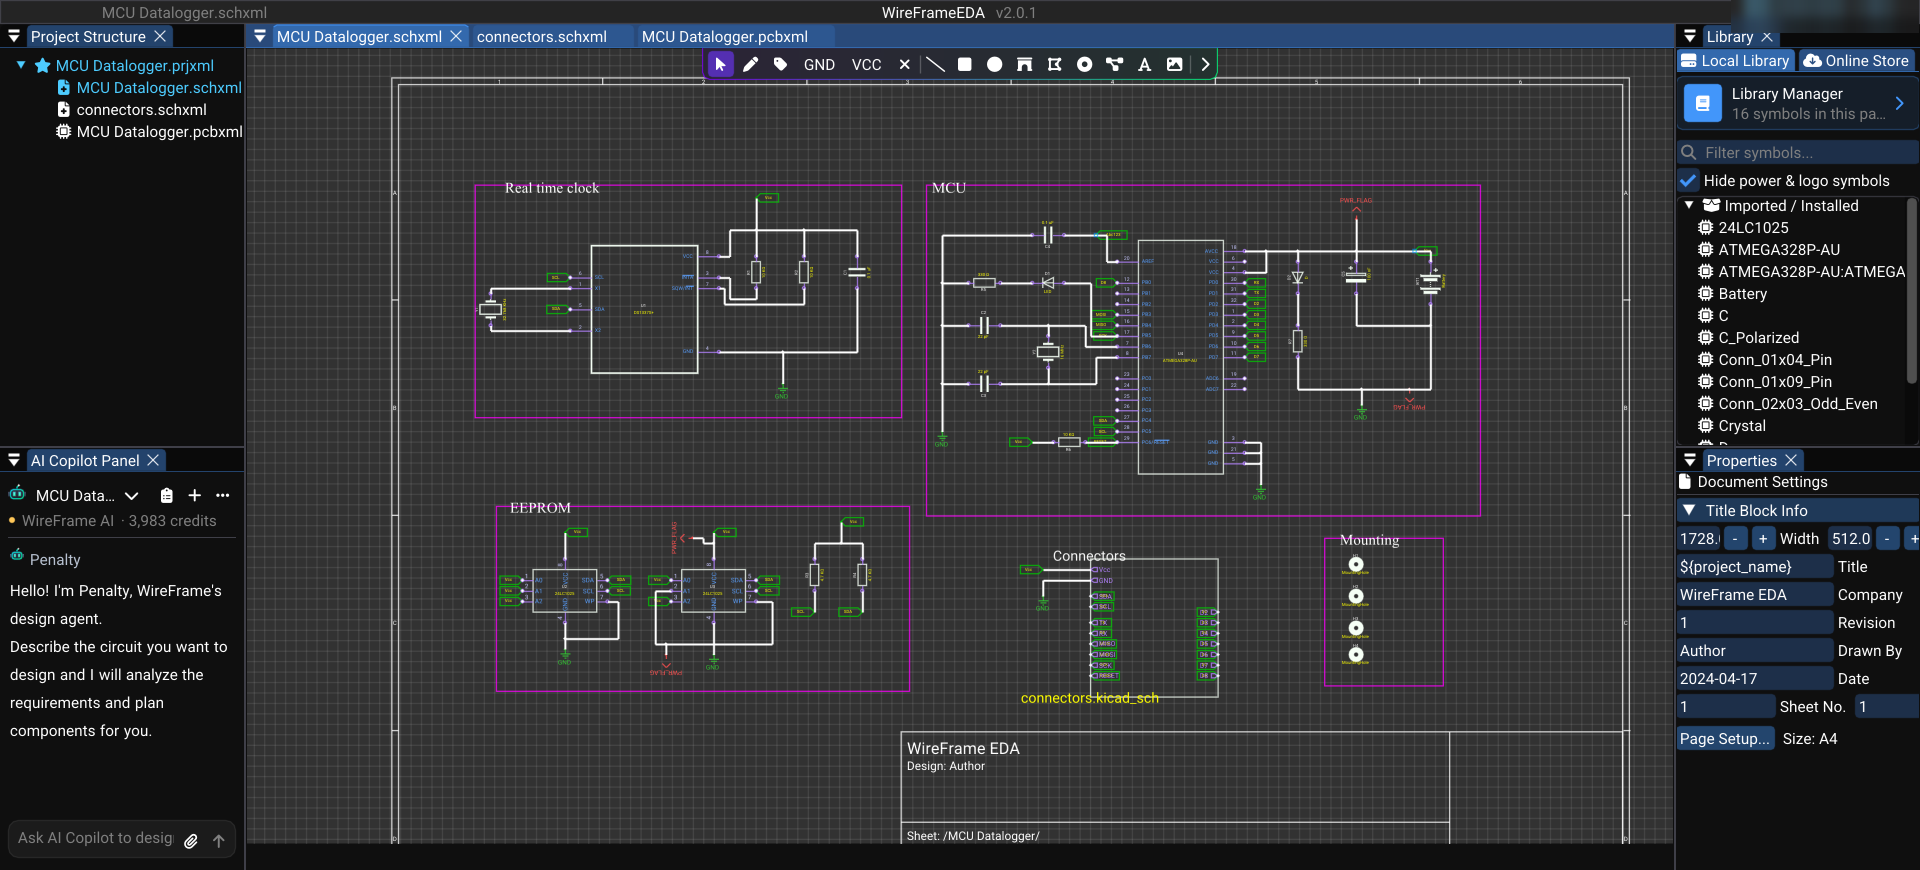
Sample board KLP4e MCU datalogger — reading a finished schematic, and what ERC says about it
The ATmega328P datalogger from "KiCad Like a Pro" (4th ed.), imported into WireFrame EDA — its two schematic sheets, why a working design still shows 18 ERC errors, and the small two-layer board.
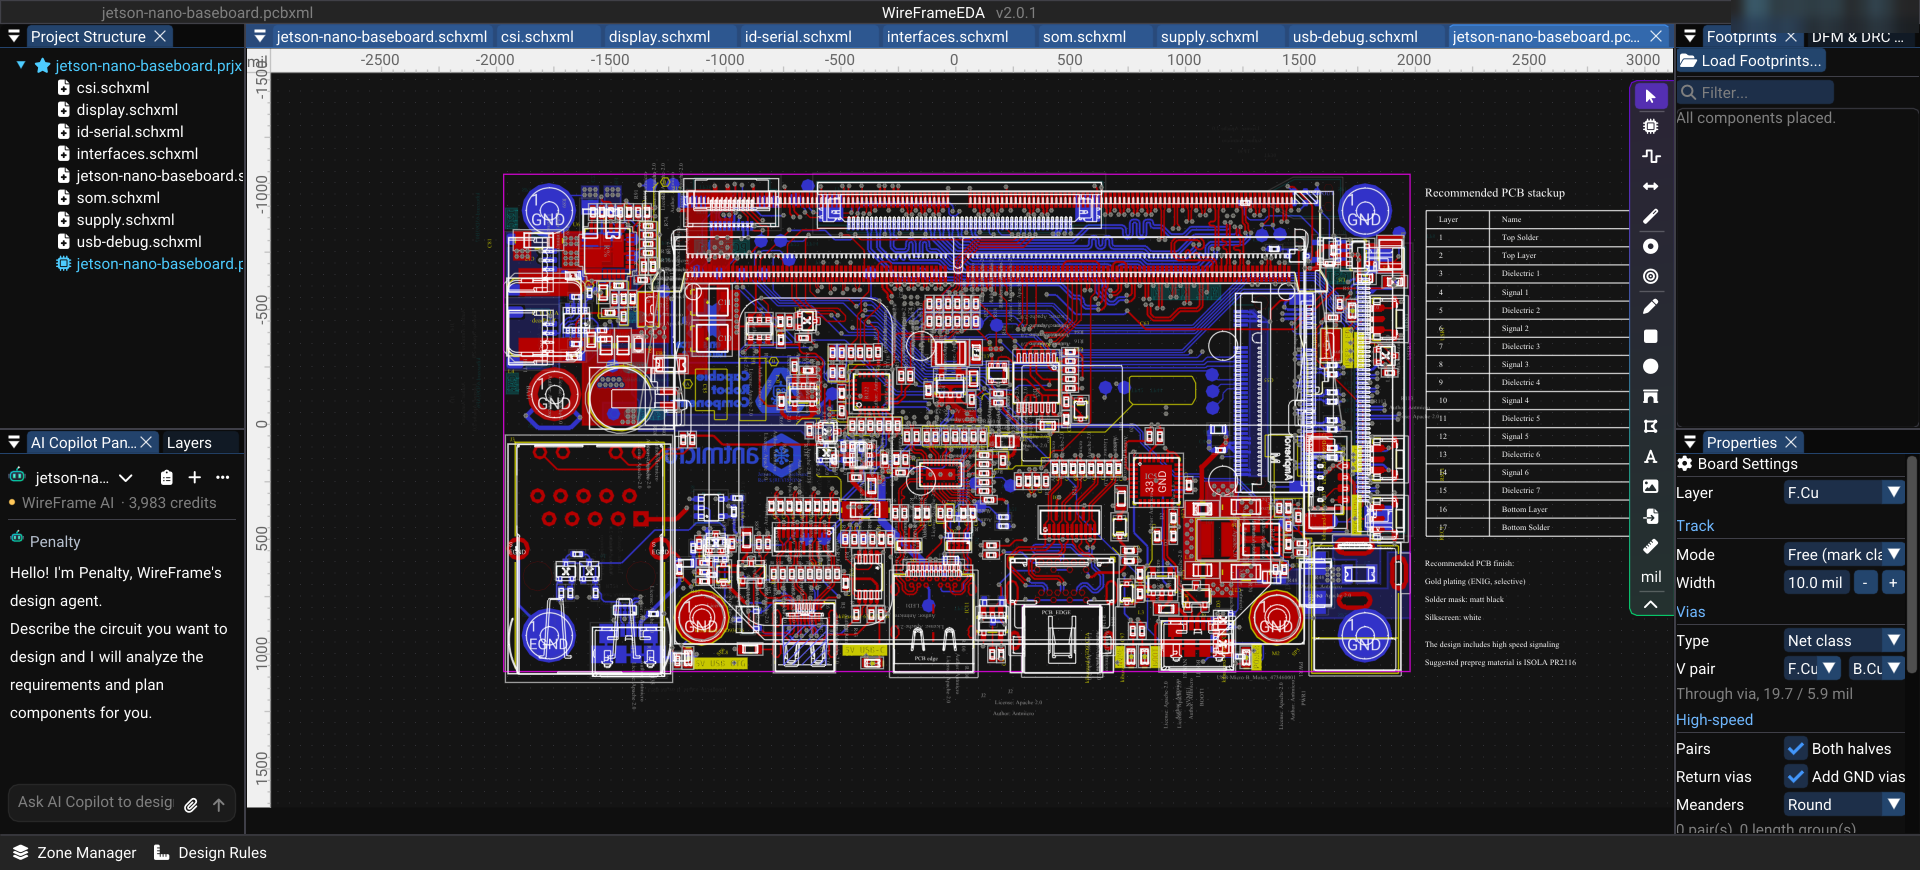
Sample board Jetson Nano baseboard — an 8-layer SO-DIMM carrier, opened in WireFrame EDA
Antmicro's open-source baseboard for the Jetson Nano and Xavier NX modules, imported from KiCad into WireFrame EDA — what is on its eight layers and what WireFrame measures on it.
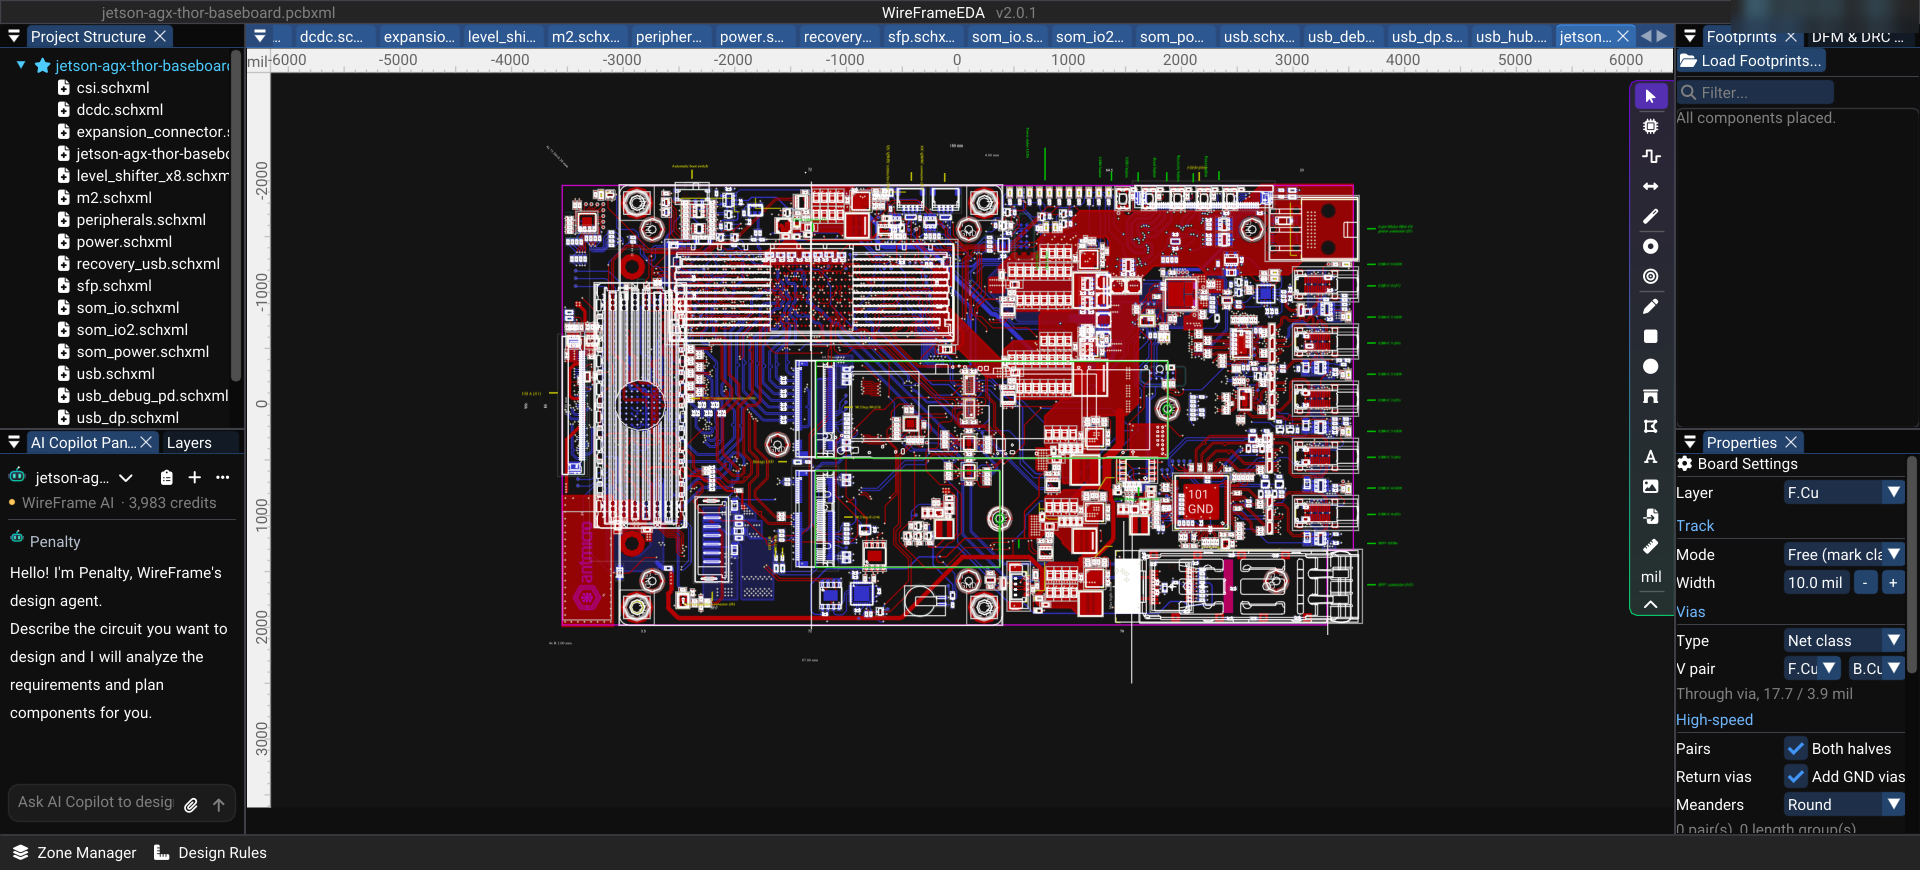
Sample board Jetson AGX Thor baseboard — 10 layers and 1124 parts, opened in WireFrame EDA
Antmicro's open-source carrier for the NVIDIA Jetson AGX Thor module, imported from KiCad into WireFrame EDA — its ten-layer stackup, length-tuned camera pairs and the numbers WireFrame measures on it.
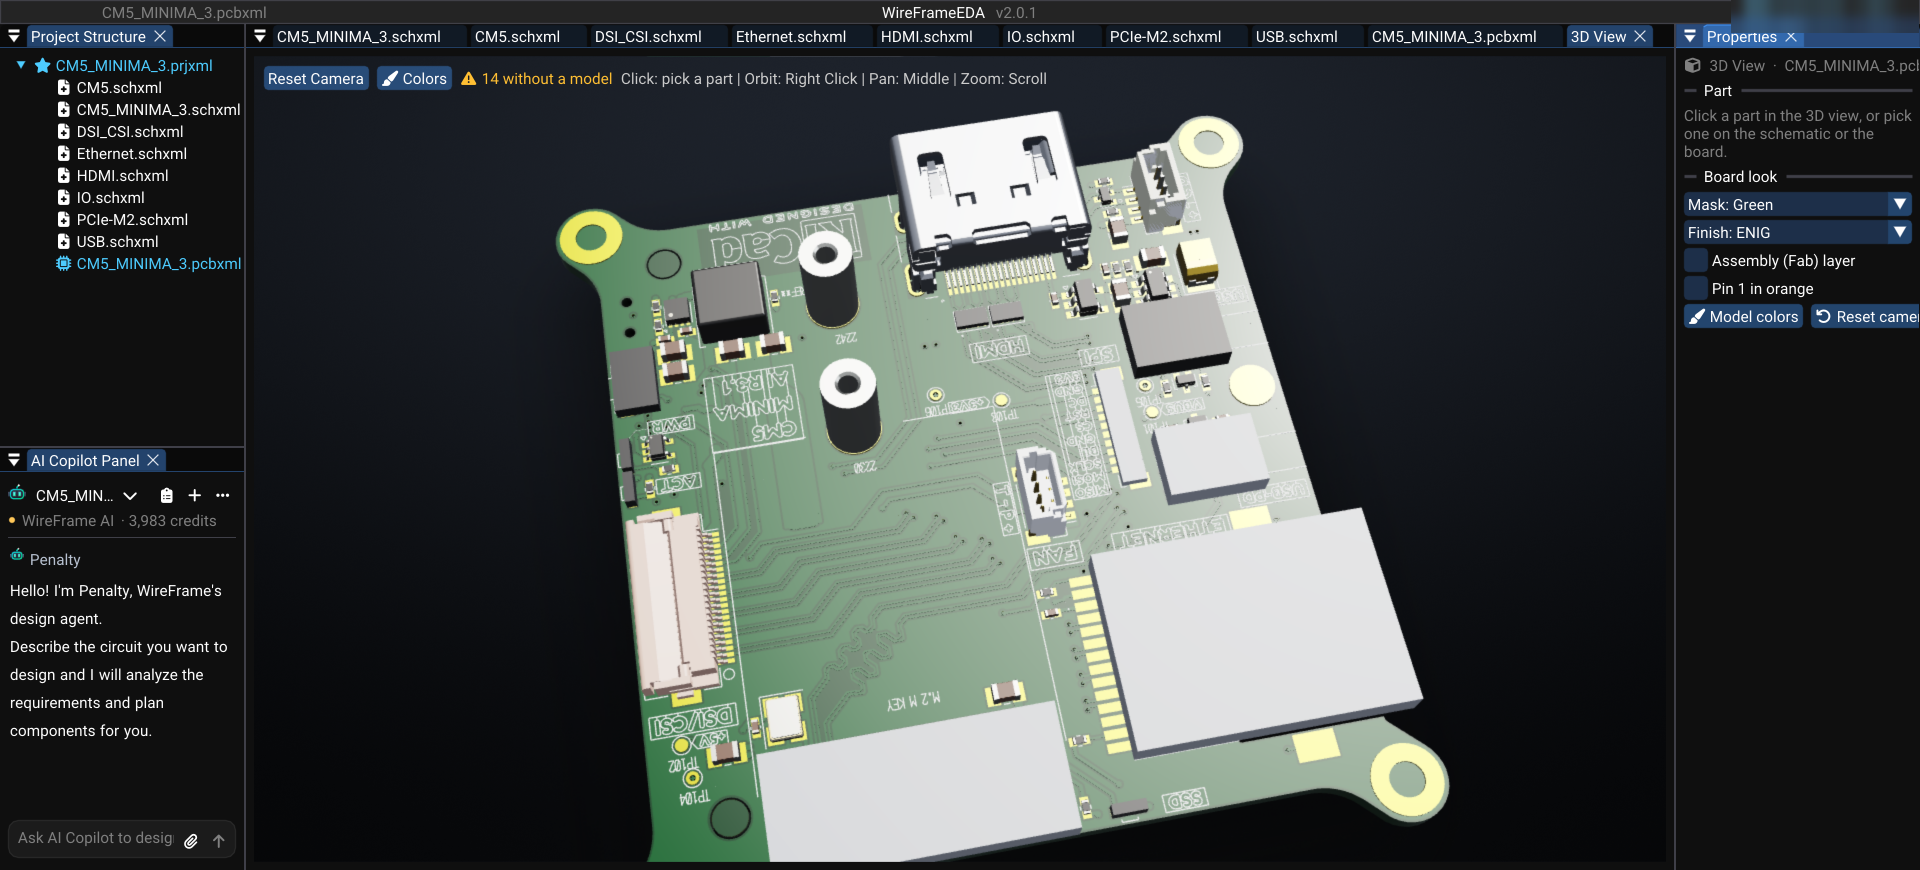
Sample board CM5 Minima — a 6-layer Raspberry Pi CM5 carrier, in 2D and 3D in WireFrame EDA
The CM5 Minima carrier for the Raspberry Pi Compute Module 5, from KiCad's demo projects, imported into WireFrame EDA — four inner planes, an M.2 slot, and the parts drawn from their 3D models.
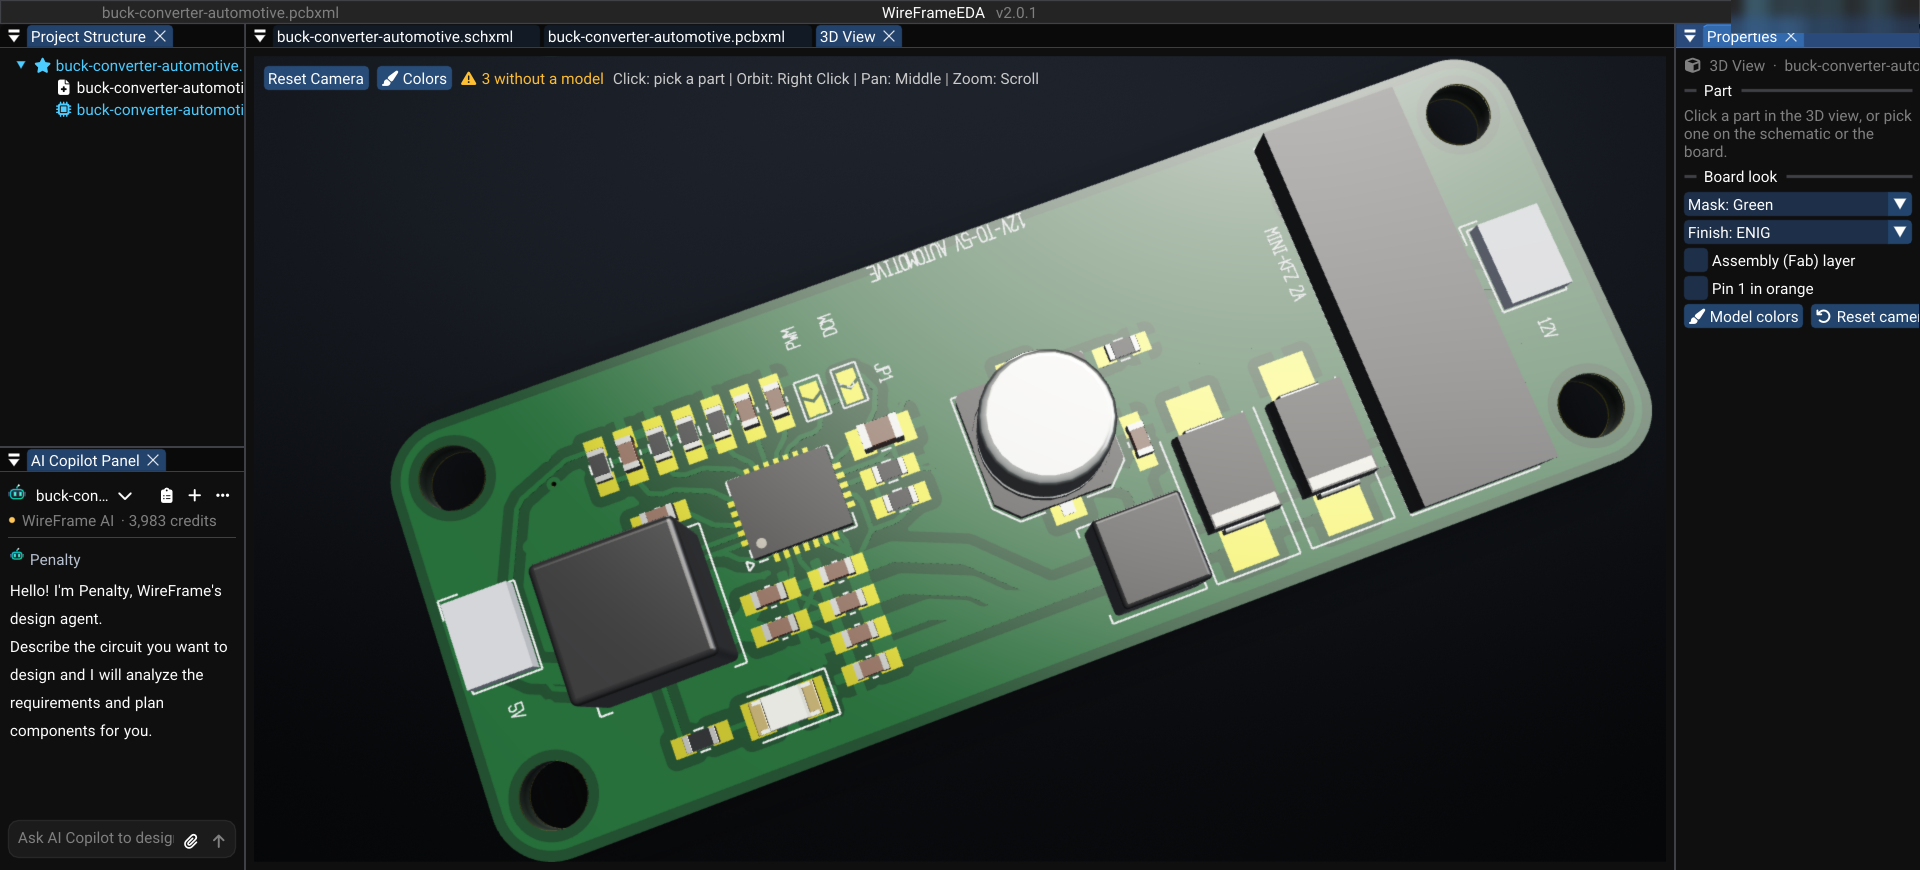
Sample board automotive buck converter — 12 V to 5 V on two layers, in WireFrame EDA
A small open-source MAX17574 buck converter for 12 V vehicles, imported from KiCad into WireFrame EDA — fully routed, ground poured on both sides, clean DRC, and what to look at on a board this size.
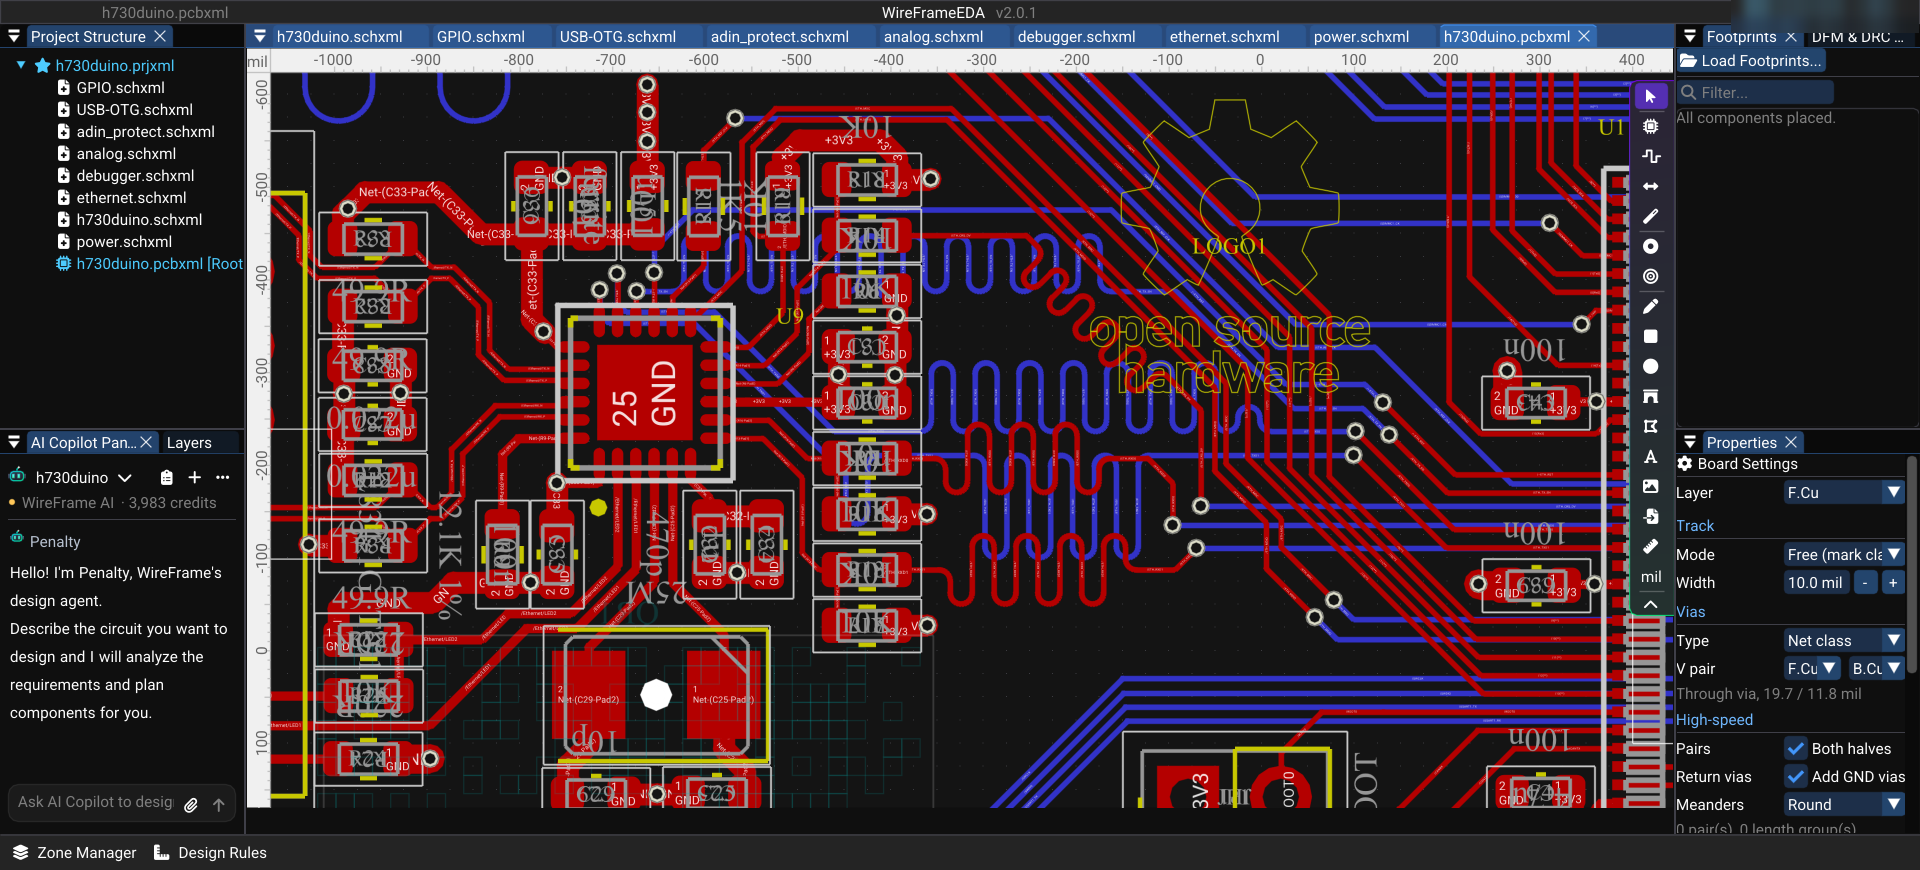
Length matching in practice — RMII and SDMMC on the H730duino
Measuring the real routed lengths of the RMII Ethernet and SDMMC traces on the open-source H730duino board: seven RMII signals matched within 0.02 mm. Why, and when you don't need to.
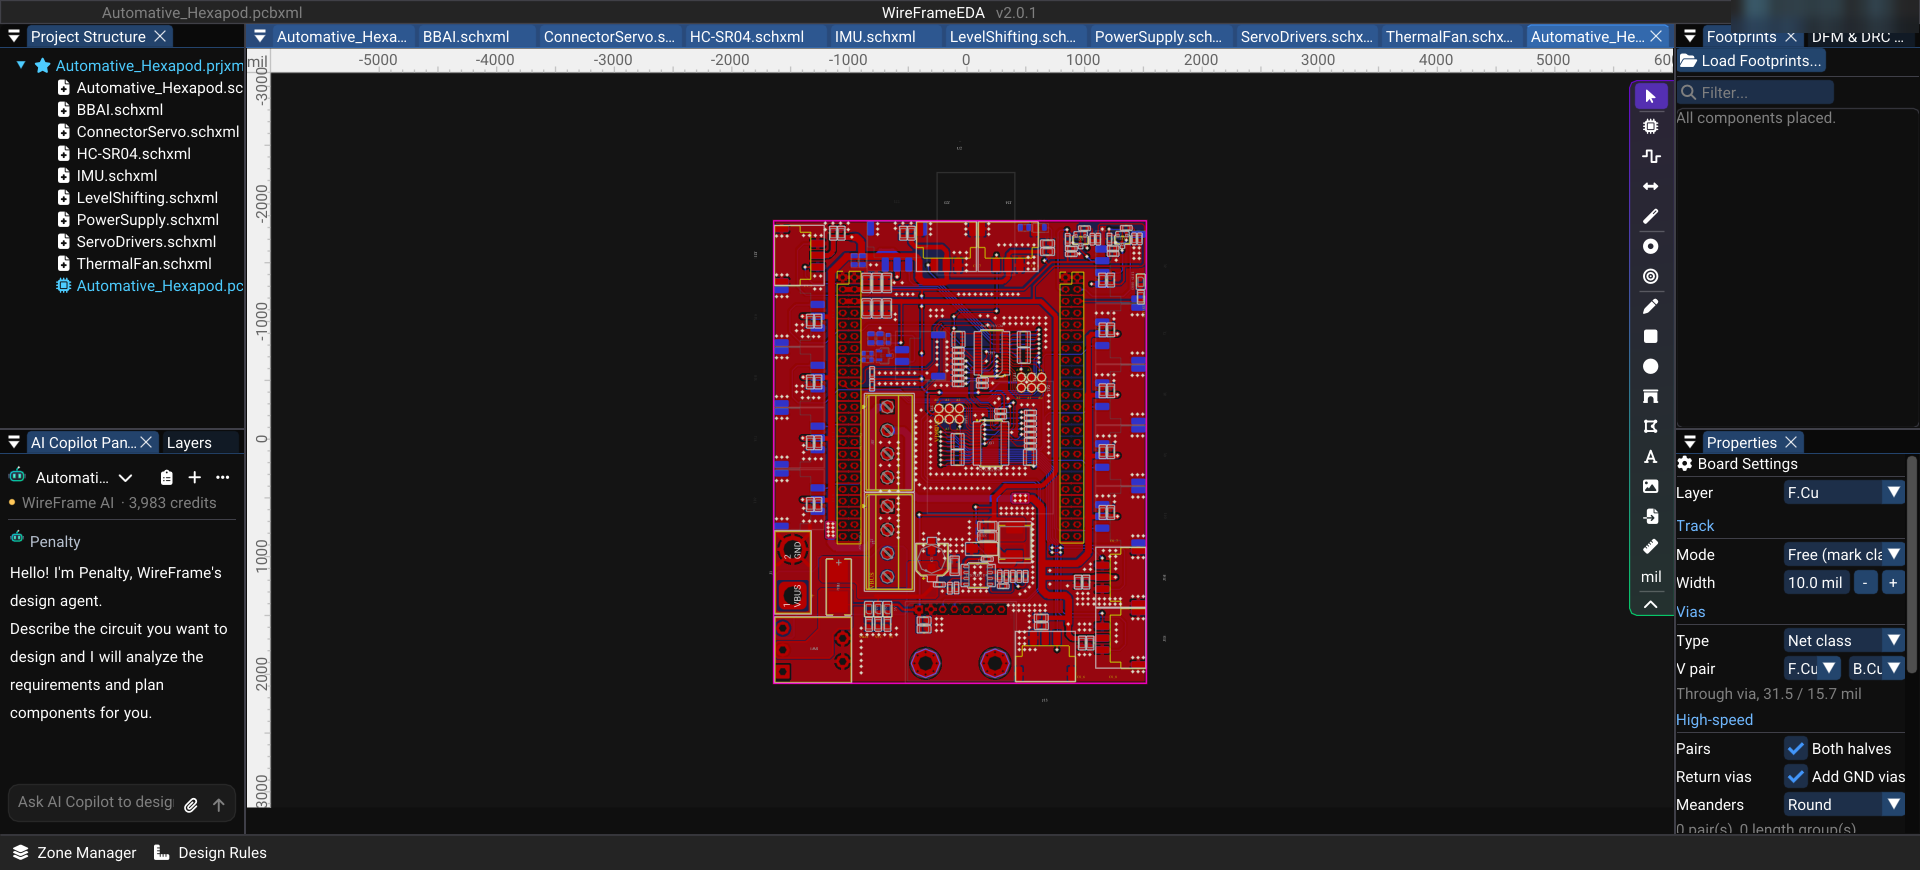
Hardware design walkthrough: 18-servo hexapod robot main board on BeagleBone AI
Reading the main board of the open-source reinforcement-autonomous-hexapod robot: BeagleBone AI, two PCA9685 driving 18 servos, an MPU6050 IMU, an ultrasonic sensor and a TPS54331 supply — opened in WireFrame EDA.
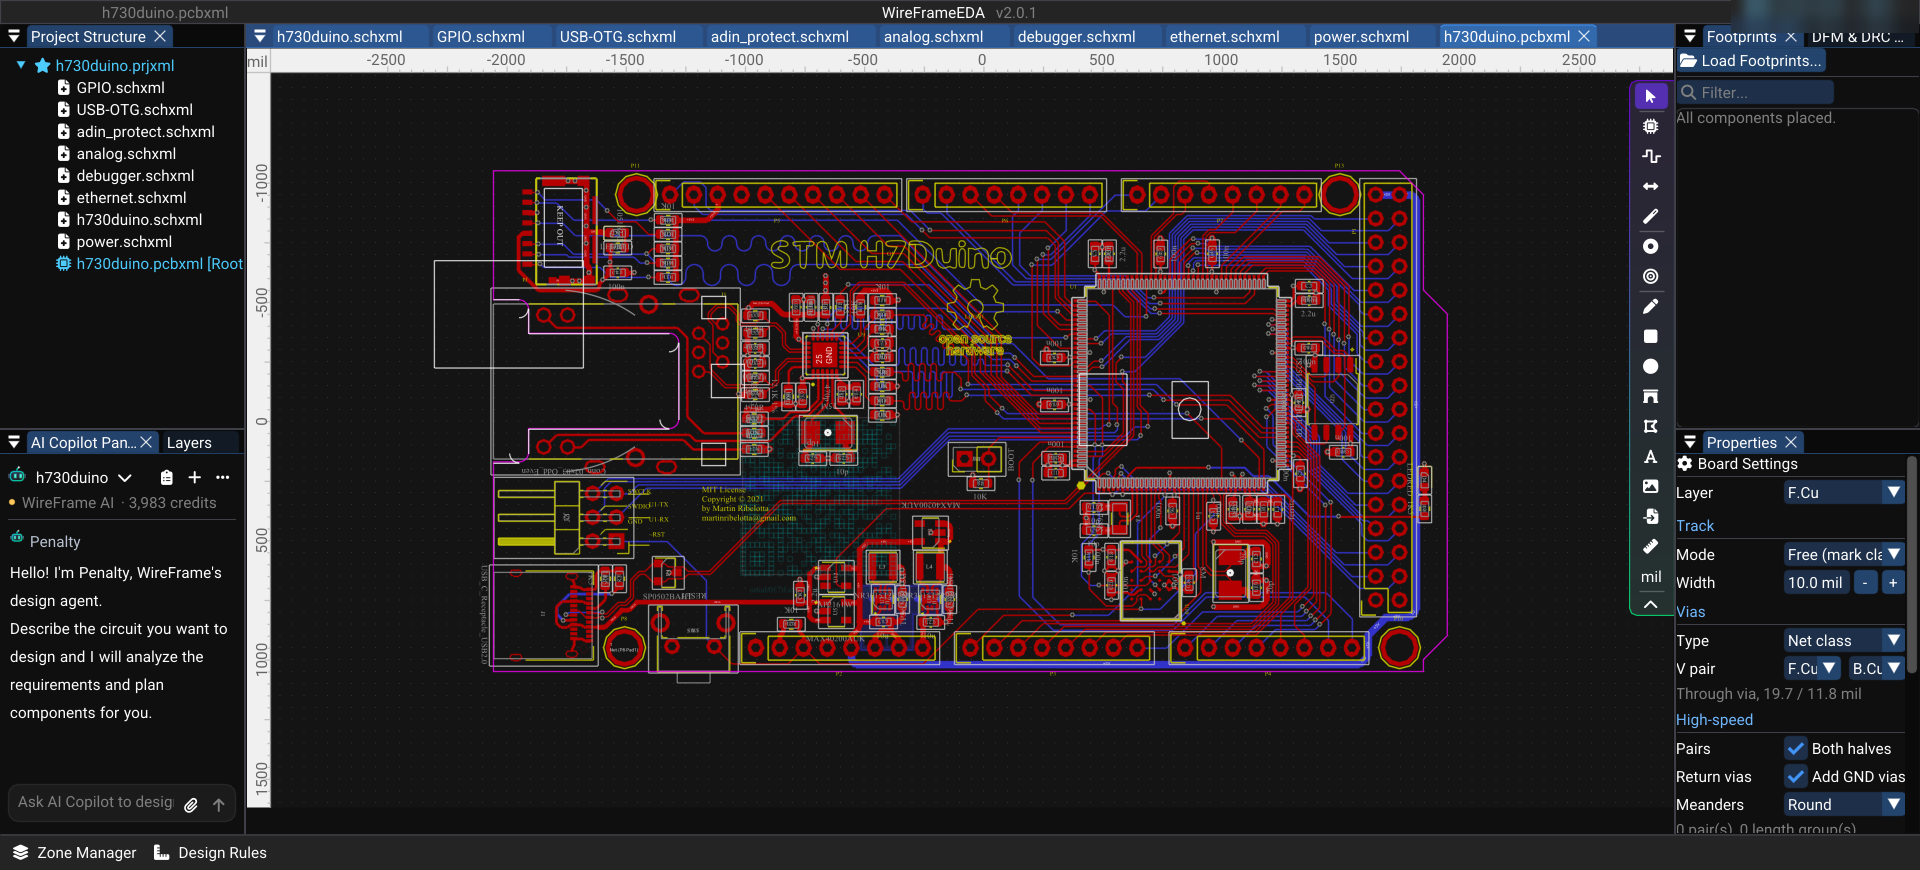
Sample board H730duino — a 4-layer STM32H730 Arduino Mega-format board, opened in WireFrame EDA
Opening the open-source KiCad project H730duino (STM32H730, Ethernet, HyperRAM, USB-C) in WireFrame EDA to read its 4-layer stackup, GND/3V3 planes, length-matched meanders and board metrics.